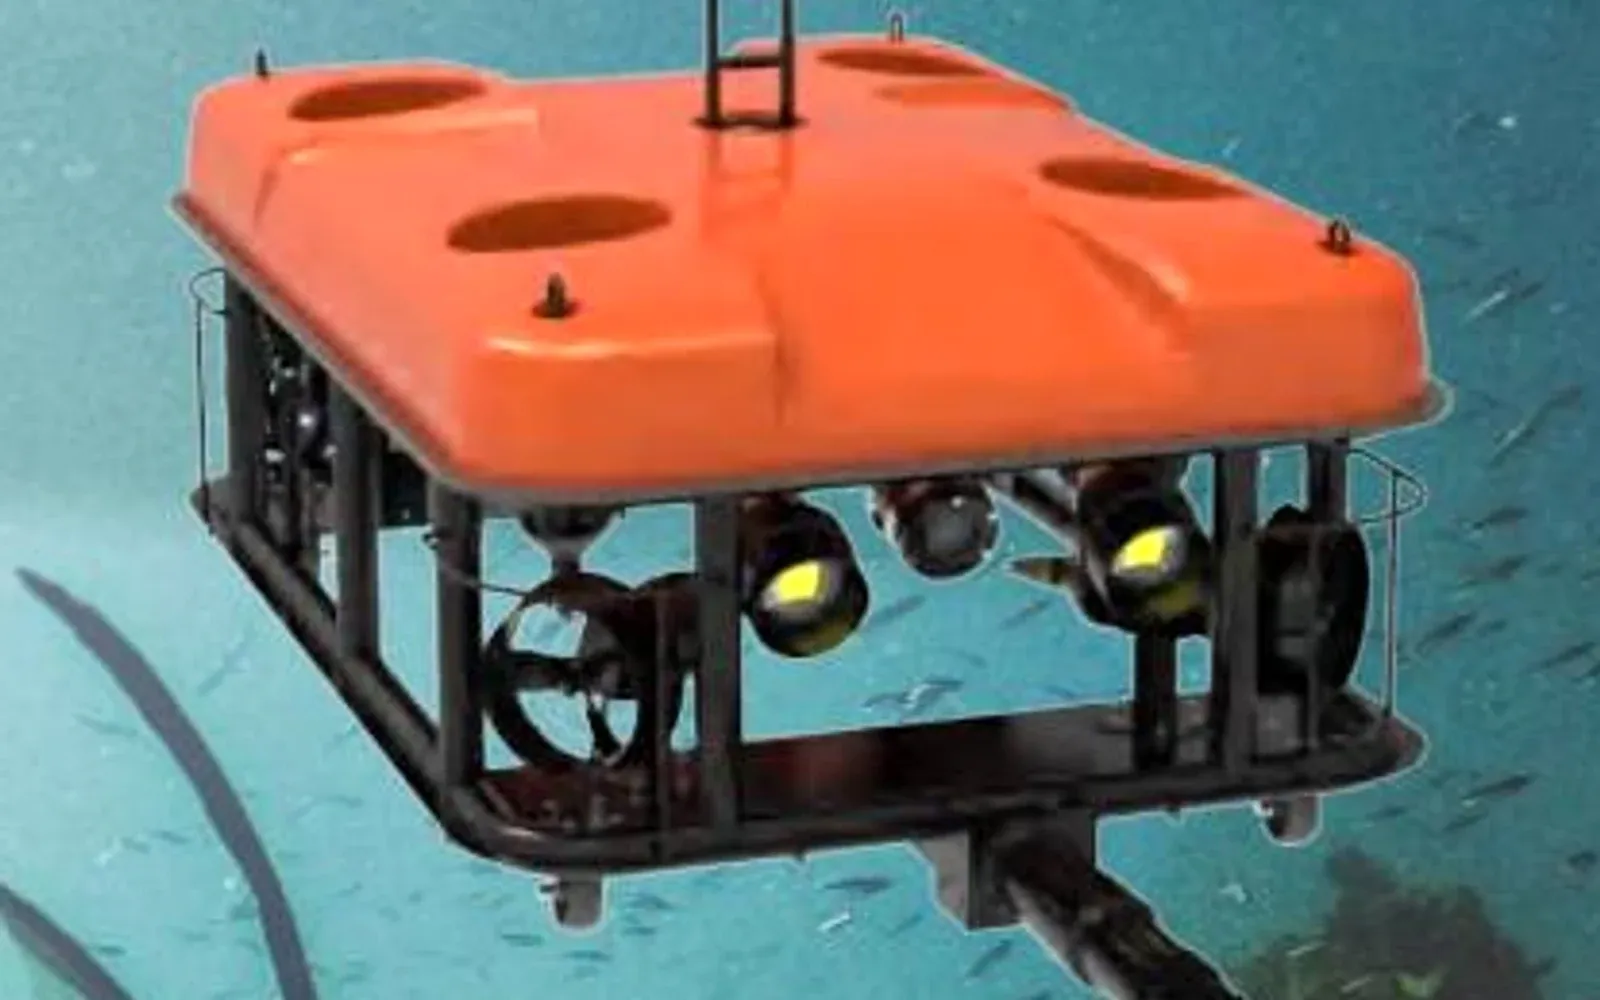
ROV ultrasonic thickness measurement is a contact-measurement workflow carried by a vehicle. The useful output combines a valid reading with material settings, probe condition and a repeatable asset location. A number displayed over video is not enough to decide whether a component needs repair.
Table of Contents
Understand what the gauge measures
An ultrasonic pulse travels through the material and returns from a reflecting boundary. With the appropriate interpretation of the echo interval, thickness is related to sound speed and round-trip time: t = cΔT / 2.
For an illustrative sound speed of 5,900 m/s and a 4.0-microsecond interval, the result is 11.8 mm. The sound speed is an assumed example value, not a substitute for the correct setting and calibration for the actual material.
The Cygnus M5 ROV manual, issue 12 describes a multiple-echo method using equally spaced return echoes and distinguishes material thickness from the initial passage through a coating. That behavior is specific to the gauge, supported probe and valid measurement conditions.
The vehicle must establish useful contact
A probe that touches the structure intermittently can produce intermittent or missing measurements. The ROV needs to approach the measurement location, orient the probe, maintain the required contact and withdraw without damaging the equipment or asset.
Probe handling, vehicle motion and the viewing angle therefore belong in the configuration decision. A capable gauge can be ineffective when its holder cannot reach the surface or the pilot cannot see the contact.
The manipulator selection guide explains reaction loads and geometry. For a thickness task, a dedicated probe holder may be more appropriate than a general-purpose arm if the surface and access are predictable.
Specify the measurement record
| Record element | Why it is needed | Decision it supports |
|---|---|---|
| Asset and measurement-point ID | Locates the reading on a component | Repeat survey and repair planning |
| Material and sound-speed setting | Defines the acoustic calculation | Interpretation of the thickness |
| Gauge, probe and mode | Preserves the measurement configuration | Repeatability and troubleshooting |
| Calibration or reference check | Connects the setup to a known reference | Instrument confidence |
| Reading validity and repeats | Separates accepted values from poor contact | Selection of usable observations |
| Image and position context | Shows where and how the reading was taken | Review and reacquisition |
Keep a missing or invalid reading distinct from a zero-thickness value. The latter has a completely different engineering meaning. If the integration exports a status field, preserve it through the entire data pipeline.
A repeatable grid or named feature can be more useful than a loosely located reading with many decimal places. Position uncertainty matters when the next survey needs to return to the same damaged area.
A practical grid can combine a structural reference (a weld line, frame number or plate boundary) with a measured offset and a photograph. The point identifier should remain stable if the coating is renewed or the probe is changed. That is what allows a later survey to compare the same location rather than a similar-looking patch of steel.
Combine methods without substituting them
A cathodic-protection survey and a thickness survey answer different questions. Electrical protection measurements, surface imagery and remaining wall thickness can inform the same integrity review, but one should not be relabeled as another.
For an underwater ROV inspection package, price the gauge, probe handler, power and data integration, location method and reporting work together. The manual’s serial output options demonstrate why the topside integration is part of the system, not an incidental accessory.
In a port asset program, give the engineer the accepted observations and their locations, including areas that could not be measured. Add the settings and configuration to the technical resources.
The final deliverable should let a reviewer trace a thickness value back to a specific surface and measurement setup. Repair thresholds then come from the asset’s engineering requirements, not from the sensor display—and an invalid reading should remain visible as a gap, not disappear from the report.
FAQs
Can a visual inspection establish remaining wall thickness?
A camera can show accessible surface condition, but it does not directly measure remaining wall thickness. Ultrasonic testing uses an acoustic measurement with suitable material, coupling and instrument settings.
Can all coatings remain in place during ultrasonic testing?
No universal rule applies. A supported multiple-echo method may measure through suitable coatings, but coating condition, material, surface and instrument mode affect whether a valid reading is obtainable.
Who decides whether a measured thickness is acceptable?
The responsible asset engineer or qualified integrity process applies the relevant design, material and service criteria. The ROV measurement package should preserve enough context for that assessment.
What should happen when a reading is invalid?
Record it as invalid with the reason, keep it in the survey record, and re-measure if access allows. Do not substitute zero or omit the point, because the gap itself is information for the integrity review.